Top Explosion Proof Robot Manufacturers Worldwide?
Explosion-Proof Robot technology is changing how companies inspect refineries, chemical plants, mines, and other hazardous facilities. These machines enter areas where a small spark, hot surface, or electrical fault could create serious danger. Their value is practical. They can inspect pipelines, valves, storage tanks, and narrow service corridors while keeping workers farther from exposure.
Jan van Dijk, a leader associated with ExRobotics, explains the central principle: “Safety is not an accessory; it is the robot’s starting point.” This idea reflects real engineering practice. A credible Explosion-Proof Robot must combine certified electrical protection with dependable movement, sensing, communication, and thermal control. Buyers should examine ATEX or IECEx documentation, approved hazardous-zone ratings, battery design, camera performance, payload limits, and maintenance requirements. Certification depends on the target market and operating zone.
This guide reviews leading Explosion-Proof Robot manufacturers worldwide. It considers field experience, product design, inspection accuracy, remote operation, service support, and evidence from industrial deployments. A robot may look impressive in a demonstration. Dust, rain, glare, uneven flooring, and weak wireless signals can expose its weaknesses quickly. No ranking is perfect. Product data may change, and some manufacturers disclose more technical information than others. That limitation deserves attention. The strongest supplier is not always the largest name. It is the company that matches certified equipment, operator training, and reliable support to the site’s actual hazards.
What Are Explosion-Proof Robots and Where Are They Used?
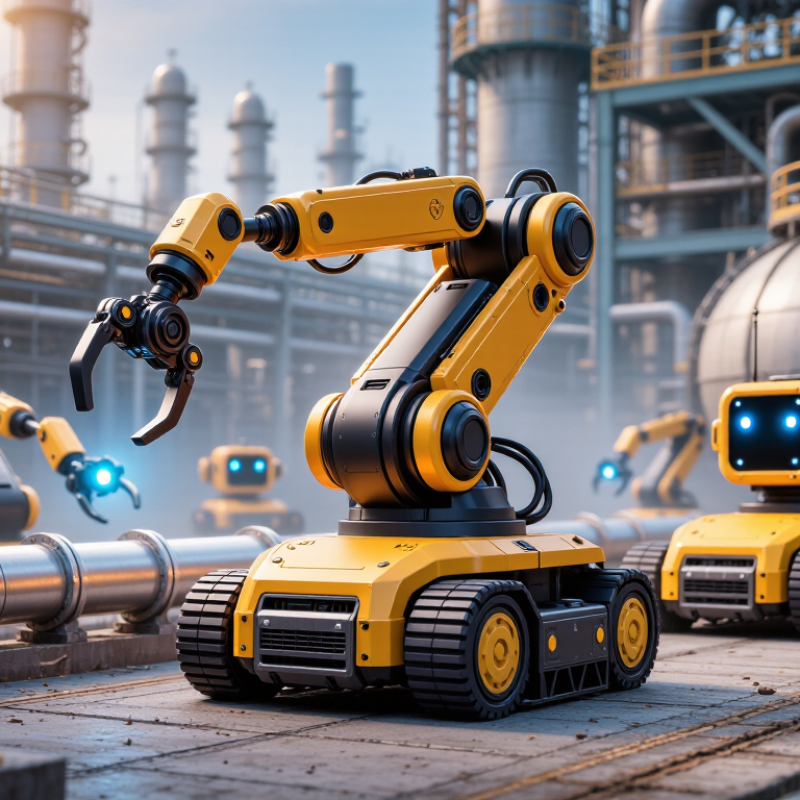
Explosion-proof robots are specialized machines designed to operate where flammable gases, vapors, or combustible dust may create ignition risks. Their sealed housings, protected electrical systems, and controlled surface temperatures help prevent sparks from starting a fire. However, “explosion-proof” is not a universal label. Each robot must match the site’s hazardous-area classification, gas group, temperature rating, and operating conditions.
These robots are used in refineries, chemical processing plants, paint facilities, storage terminals, and some grain-handling environments. They can inspect pipes, monitor valves, detect gas leaks, capture thermal images, and examine narrow or elevated spaces. A tracked robot may cross a dusty floor, while a compact unit can inspect tanks or confined equipment. In my experience, remote inspection reduces worker exposure, but it does not remove every risk. Battery limits, signal loss, difficult terrain, and sensor calibration still matter. That part is sometimes underestimated.
Tips: Check certification before deployment. Confirm the robot suits the exact hazardous zone. Review charging procedures, maintenance records, and communication limits. Test it with trained operators in a controlled area. Keep a manual backup plan. Small oversights can become serious.
Key Safety Standards for Explosion-Proof Robot Design
Explosion-proof robot design begins with the hazardous area, not the robot’s marketing name. Manufacturers should identify gas, vapor, or dust risks before selecting motors, batteries, sensors, and controllers. Area classification determines the required protection method and equipment protection level. It also affects temperature limits and permissible surface heating.
Relevant frameworks may include ATEX, IECEx, and applicable national electrical safety codes. Compliance is not achieved by adding a sealed cover. Engineers must control ignition sources through certified enclosures, protected cable glands, reliable grounding, and suitable battery isolation. Pressurized or purged compartments require monitored airflow and automatic shutdown functions. Every joint deserves attention. A small seal failure can defeat an otherwise careful design.
Testing should examine impact resistance, ingress protection, thermal behavior, static discharge, and abnormal operating conditions. Documentation should connect each component to its certificate and inspection requirement. Field trials are equally important because oil residue, dust buildup, vibration, and cleaning chemicals change real performance. A laboratory result may not predict a difficult plant floor.
Good manufacturers also design maintenance into the safety case. Technicians need clear inspection intervals, replacement rules, and fault records. Remote diagnostics can reduce exposure, but wireless equipment must fit the site’s approved protection concept. The difficult truth is that no checklist captures every risk. Human error remains possible, and even certified equipment needs disciplined installation and recurring review.
Leading Explosion-Proof Robot Manufacturers Worldwide
Leading explosion-proof robot manufacturers worldwide focus on safety, reliability, and practical field performance. Their systems support inspection, maintenance, and material handling in hazardous industrial environments. Experienced manufacturers design sealed joints, protected wiring, and durable outer housings. These details matter near dust, vapors, or flammable gases.
Strong manufacturers usually offer equipment tested against recognized international requirements, such as ATEX or IECEx, where applicable. They also explain certification limits clearly. A robot approved for one hazardous zone may not suit another. Buyers should examine temperature ratings, gas groups, ingress protection, payload, and operating duration. Technical documentation should be specific, not decorative.
Field experience separates serious suppliers from simple equipment sellers. A useful demonstration may include a narrow pipe corridor, poor lighting, radio interference, and a wet concrete floor. Service teams should provide training, spare parts, inspection schedules, and traceable maintenance records. Remote operation must remain stable when signals weaken. No manufacturer gets every detail right. A laboratory test can miss a blocked wheel or overheated motor in daily work. For this reason, independent risk assessment and site trials remain valuable before purchase.
Top Explosion-Proof Robot Manufacturers Worldwide
Gas temperature-class reference for evaluating explosion-proof robotic systems
Explosion-proof robots used in hazardous areas must be selected according to the required protection level, including the maximum permitted surface temperature. The IEC 60079-0 gas temperature classes range from T1 at 450°C to T6 at 85°C. A lower permitted surface temperature generally indicates stricter requirements for applications involving more easily ignitable gases or vapors. Actual robot selection should also consider zone classification, equipment protection level, gas group, ingress protection, and applicable ATEX or IECEx certification.
Reference: IEC 60079-0 gas temperature classifications. Values represent the maximum equipment surface temperature for each class.
How to Compare Explosion-Proof Robot Models and Suppliers
Top Explosion Proof Robot Manufacturers Worldwide?
Comparing explosion-proof robot models requires more than checking payload and reach. Start with the hazardous-area certification and its exact scope. Confirm the gas or dust classification, temperature rating, enclosure protection, and permitted installation conditions. A robot may be certified for one environment but unsuitable for another. Read the certificate, not only the sales sheet.
Test the complete system, including the controller, teach pendant, cables, connectors, and end-of-arm tooling. Measure cycle time with the real payload, not an ideal laboratory load. Check wrist torque, repeatability, cleaning access, and heat behavior during long shifts. Small details matter. For example, a poorly routed cable can increase maintenance work and create avoidable downtime. I have seen teams compare reach carefully, then overlook tool weight. That mistake is expensive.
Supplier quality deserves equal attention. Request validation records, inspection procedures, spare-parts data, and technician qualifications. Ask how the supplier manages firmware updates without weakening certified protection. A factory acceptance test should reproduce your process, enclosure conditions, and safety checks. Site acceptance testing should include emergency stops, grounding, purge systems, and communication with existing equipment. Be cautious when documentation feels vague. A lower purchase price may hide limited service coverage or long parts lead times. Still, no evaluation is perfect. Dust buildup, operator habits, and future process changes can affect performance. Leave room for these realities when comparing lifecycle cost, training, and technical support.